Machine Common Sense — 2nd Place
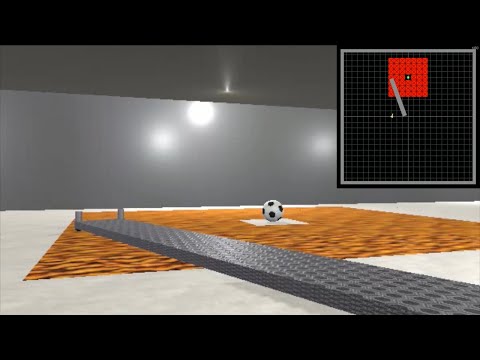
DARPA-sponsored egocentric tool-use task for object retrieval in an unknown environment.
Developed a maneuver for a robot to retrieve a ball surrounded by an untraversable “lava” region, using a tool it must locate and use correctly, based solely on egocentric vision in an unknown environment. This DARPA-sponsored project had our Oregon State University team place 2nd.